Zero anywhere
Make the current attitude the reference, or only the heading. Zeroing works on the quaternion, so angles never jump at ±180°.
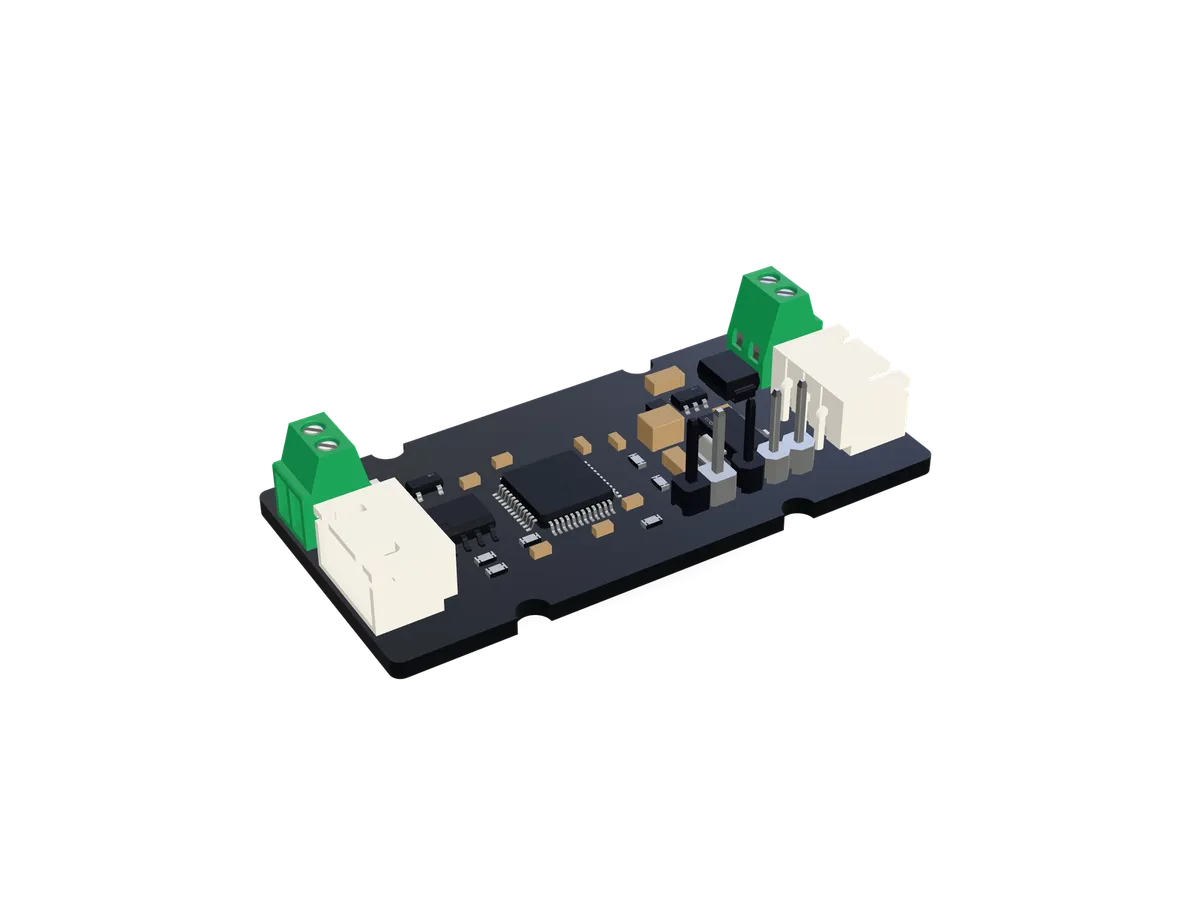
Orientation on the CAN bus
A Bosch BNO055 fuses accelerometer, gyroscope and magnetometer 100 times a second. The Tercio IMU streams the result as a quaternion and as roll, pitch and yaw on the same bus as your motors, and Tercio Control shows it live.
Tercio IMU goes on sale 1 December 2026. We’ll email you the moment it does.
Make the current attitude the reference, or only the heading. Zeroing works on the quaternion, so angles never jump at ±180°.
Save the sensor’s calibration to flash. It is restored at every power-up, so the IMU starts calibrated.
The default fusion mode ignores the magnetometer, so stepper magnets and steel cannot pull the heading. NDOF mode adds an absolute heading where the field is clean.
Protocol v2 like the S1: it appears in Tercio Control by itself, and the Python and Arduino libraries read it in a line.