Skip to content
Flagship
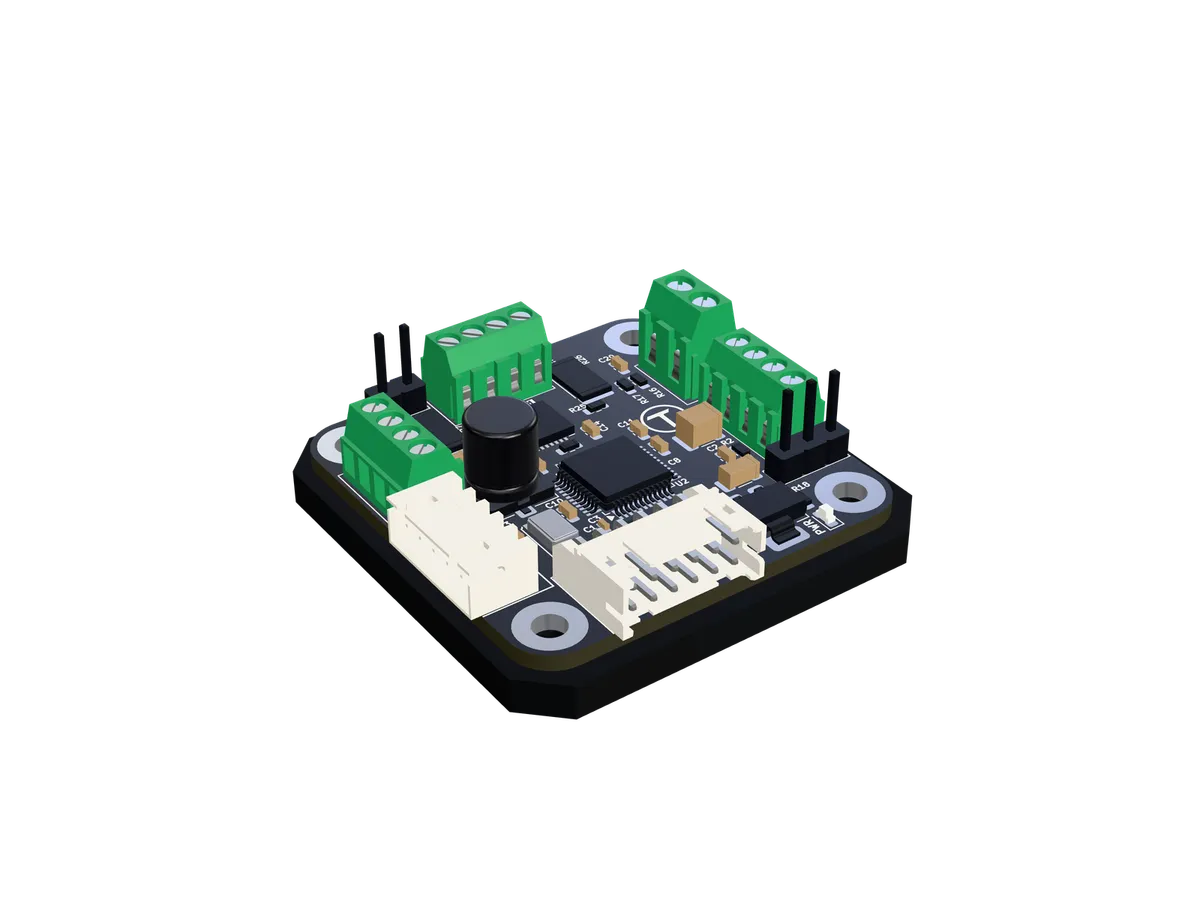
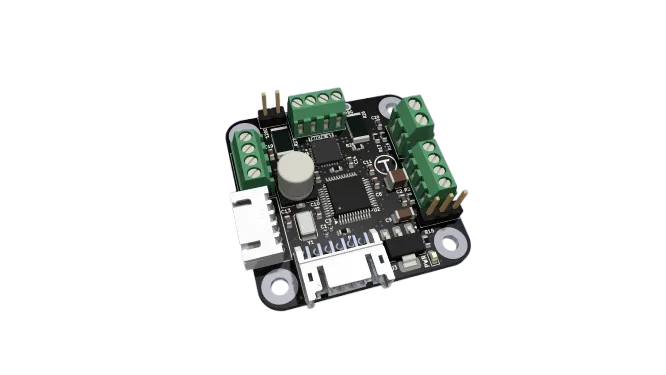
Rendering of the Tercio S1 board
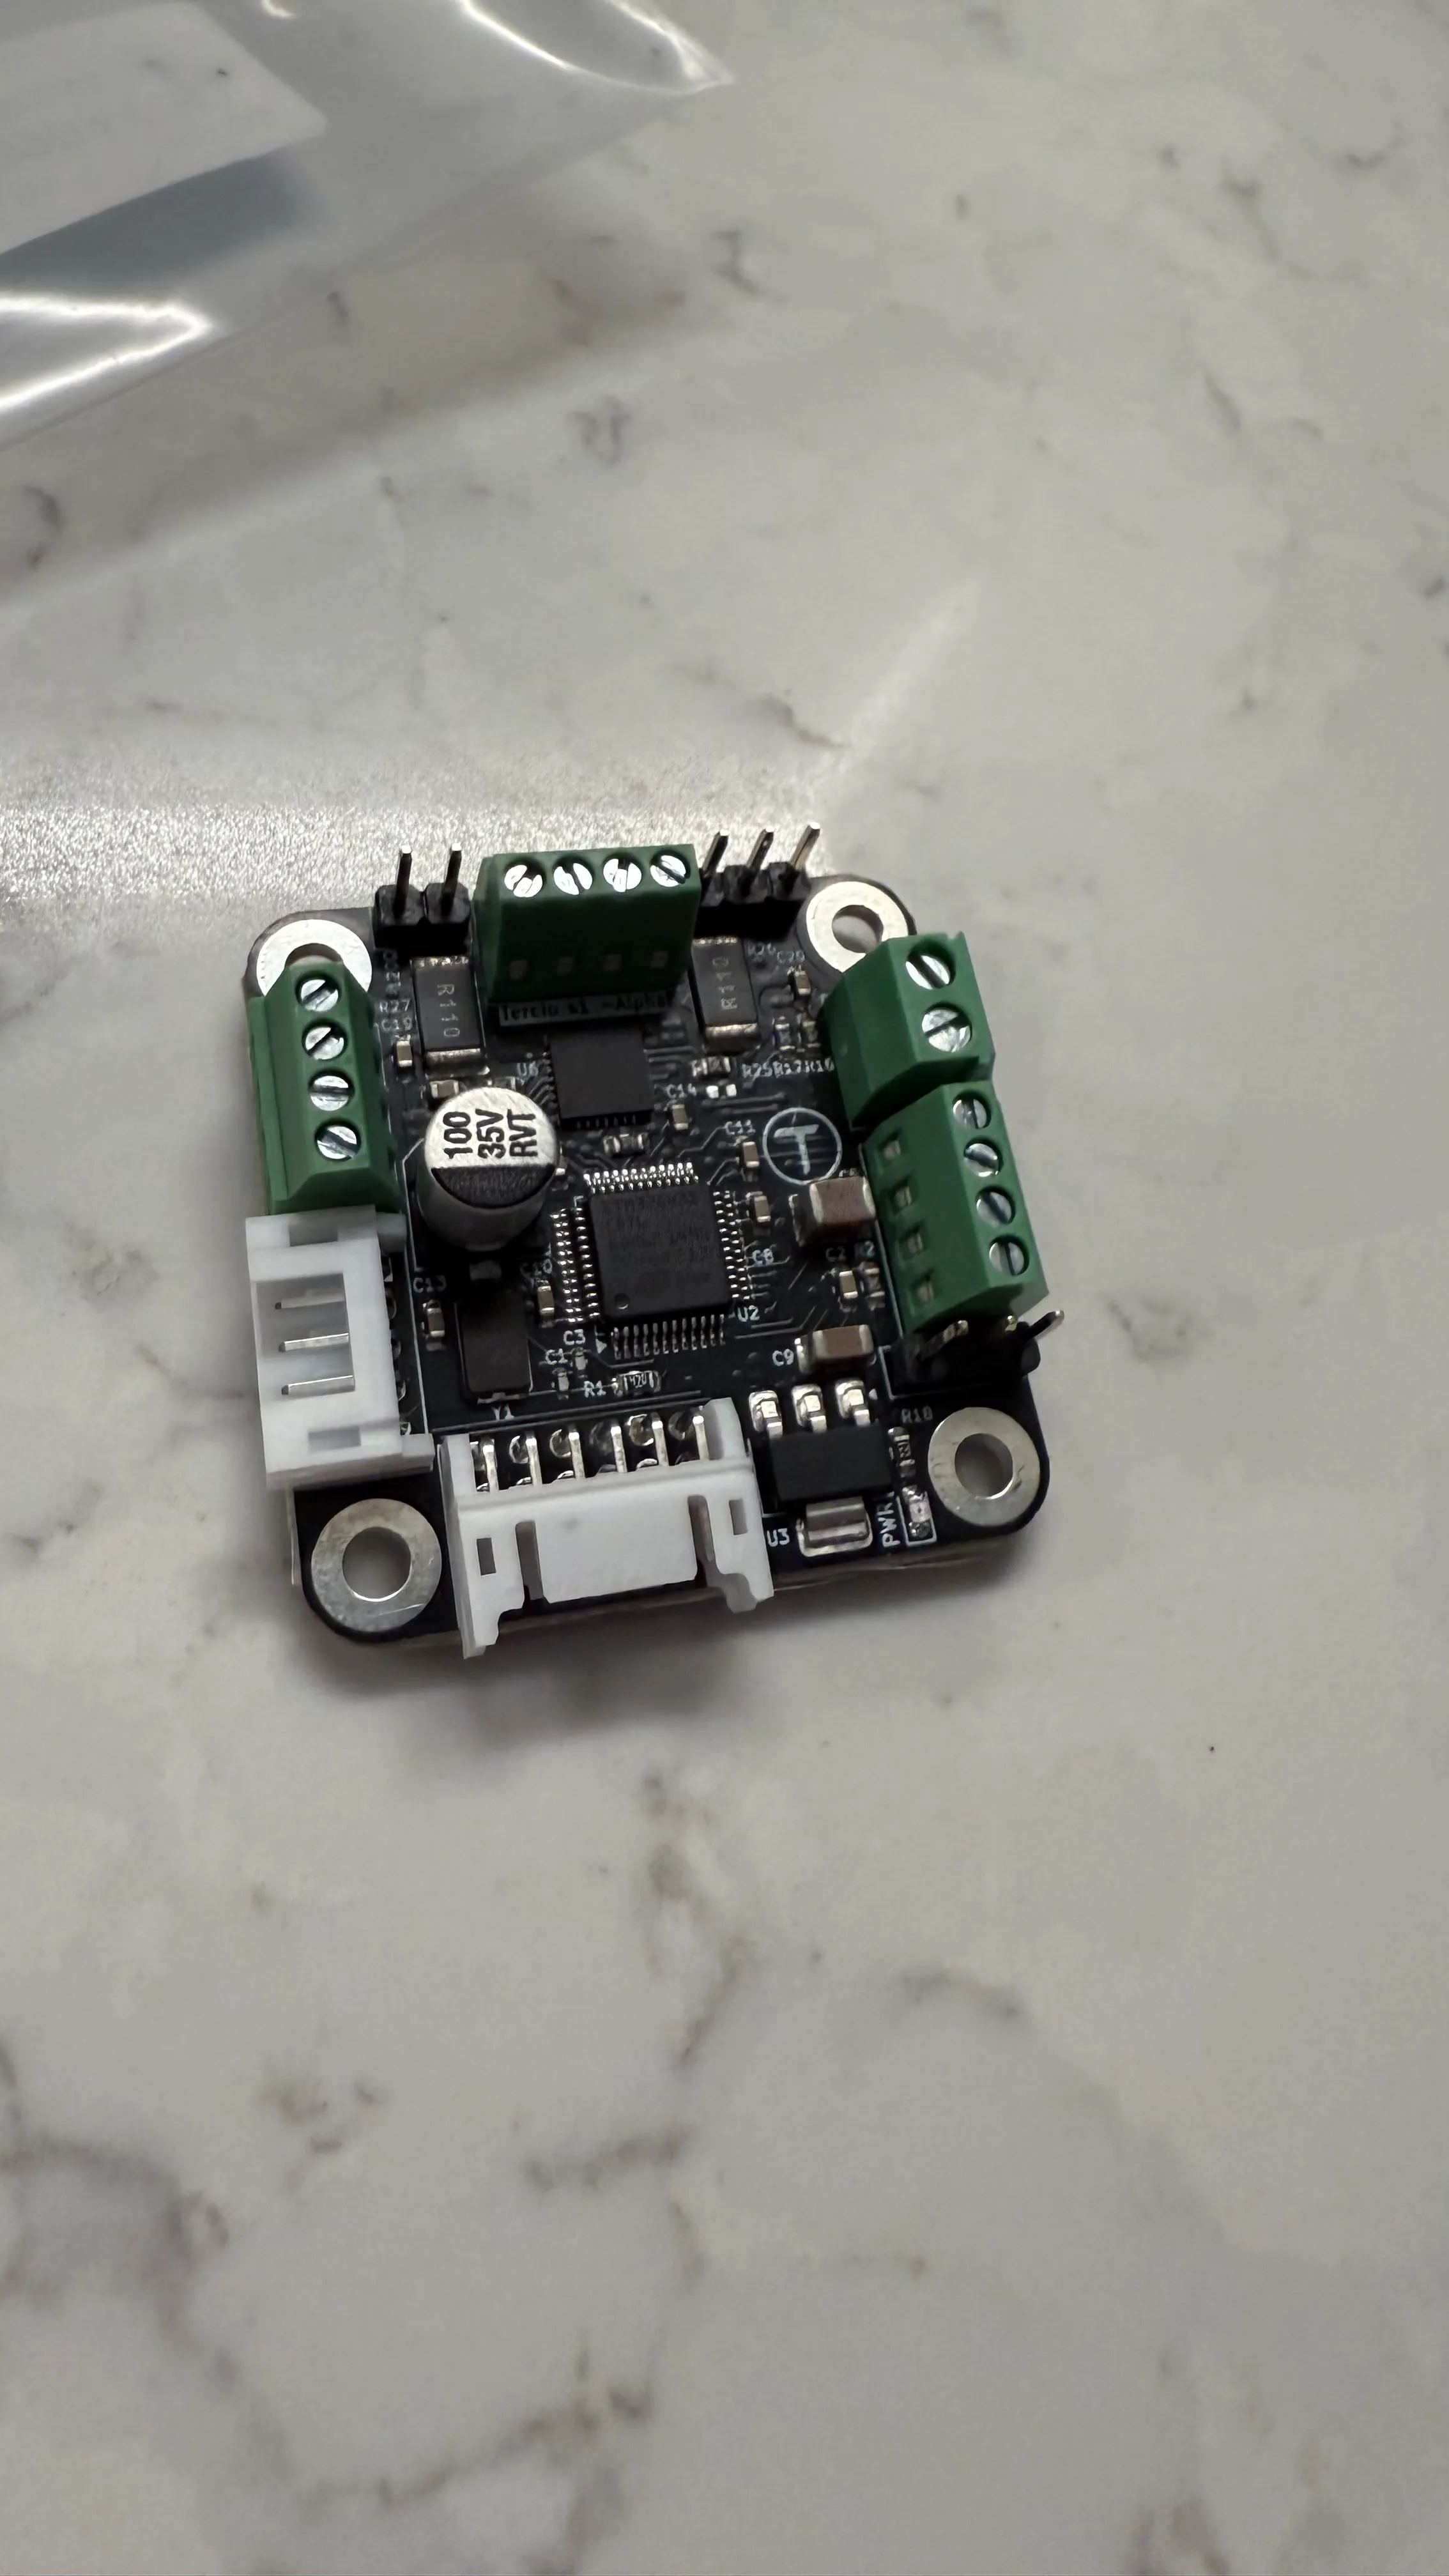
A Tercio S1 prototype on a marble surface
Drivers

Tercio S1

Closed-loop stepper driver

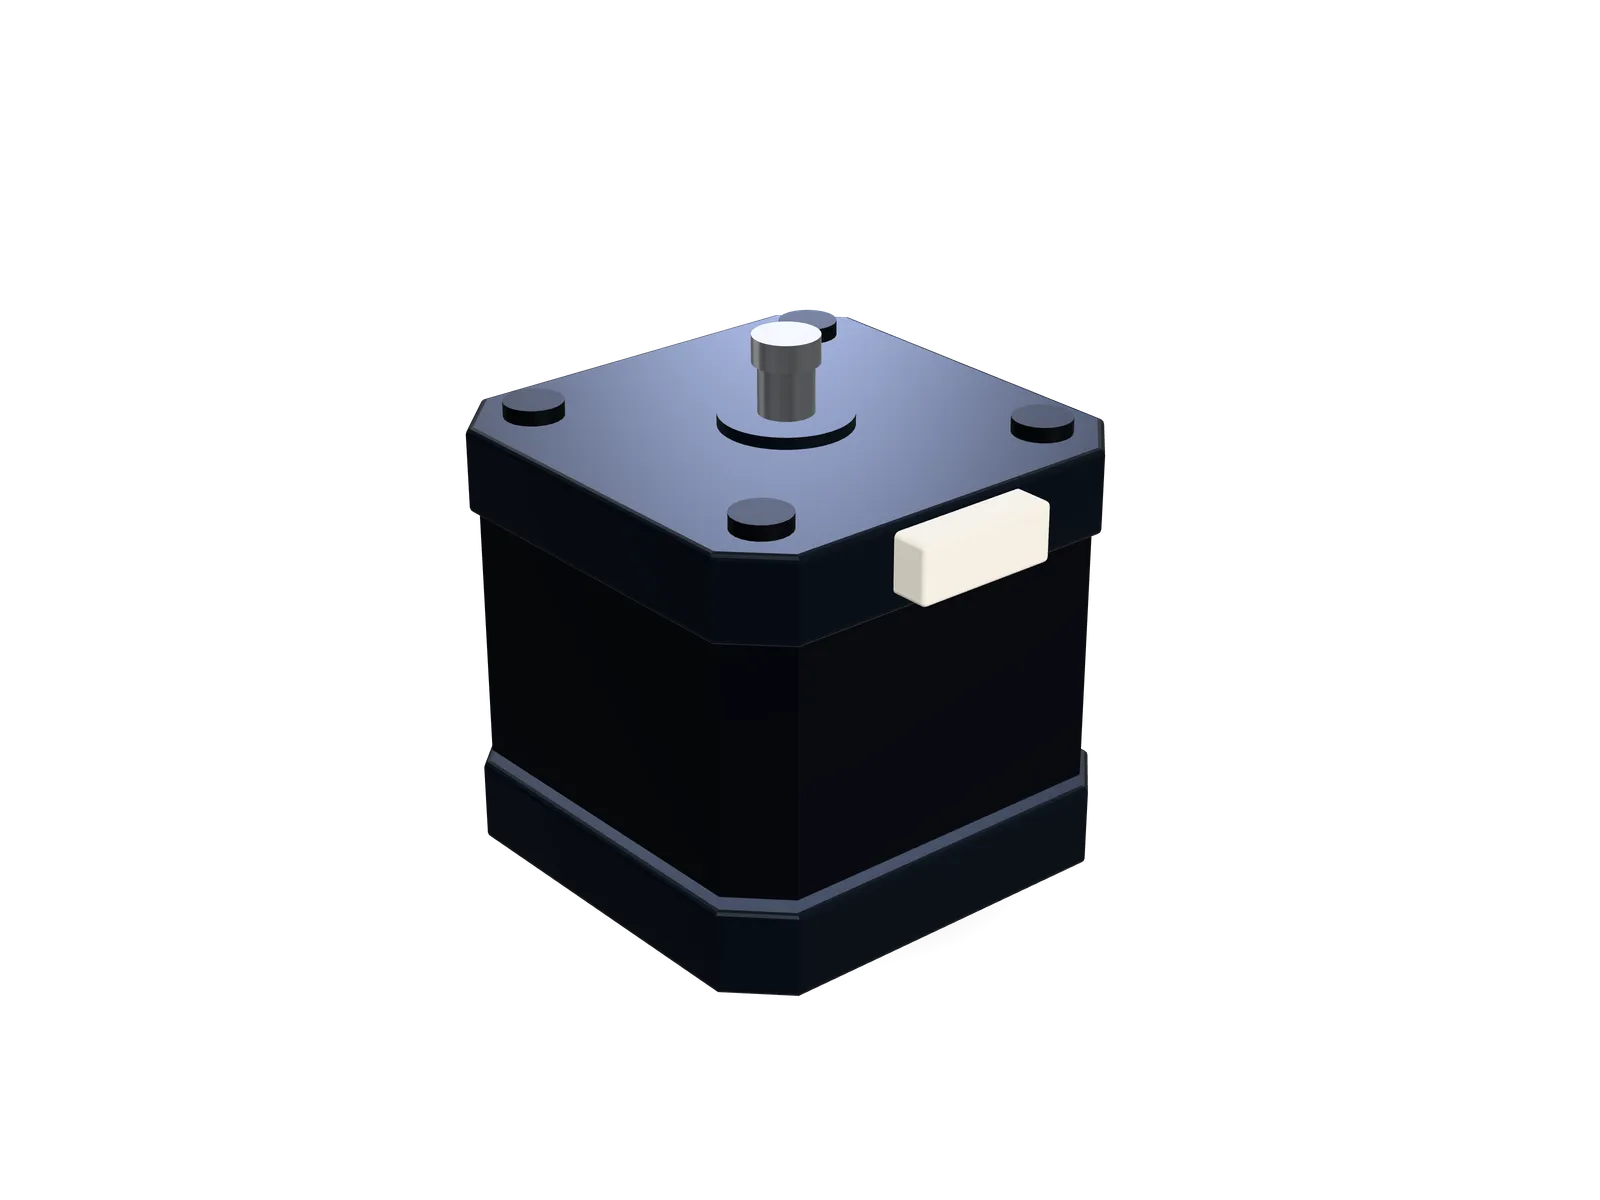
Bolts to the back of a NEMA 17 and closes the loop: a 12-bit encoder under the board reads the shaft, a 20 kHz position loop corrects every step, and CAN-FD connects up to 127 axes on one bus.

Launch price soon

Tercio S1 goes on sale 1 December 2026. We’ll email you the moment it does.

  • Open-source firmware
  • Free browser control panel
  • Python and C++ libraries
  • Shipping calculated at checkout
01

Never loses a step

A 20 kHz position loop tracks the shaft through the on-board AS5600. A blocked axis is caught as a stall and stopped, never silently shifted.
02

Tunes itself

Auto-tune runs the axis faster and faster until it slips, then keeps the fastest speed and acceleration that passed three times.

03

Quiet by default

The TMC2209 runs StealthChop at low speed and switches to SpreadCycle when the motor needs the torque.

04

Homes without switches

Home against a limit switch, or gently into a hard stop with reduced current. No switch needed.

05

Drop-in step/dir

Configure once over CAN, then drive it from any 3.3 V step/dir controller while it keeps the loop closed.

06

Open firmware

GPL-3.0 firmware built with PlatformIO, plus Python and Arduino C++ libraries and a browser control panel.
Specifications

The details.

In the box
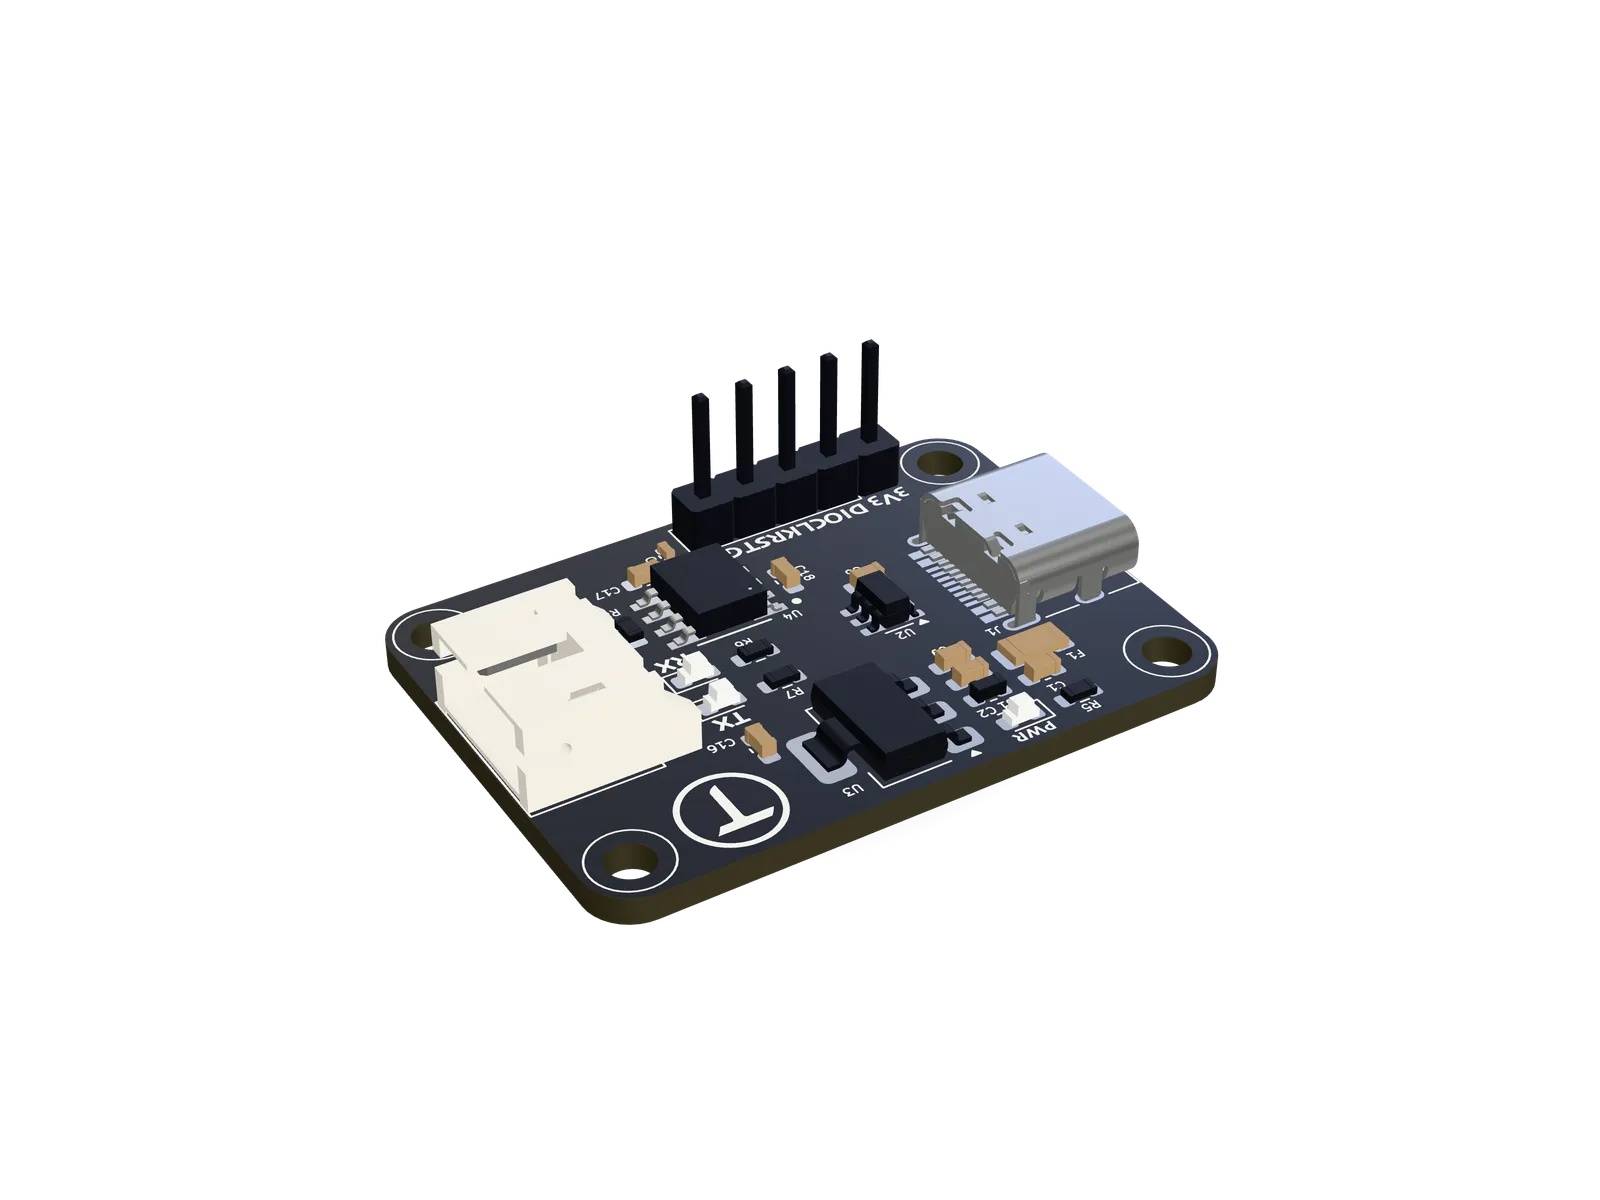
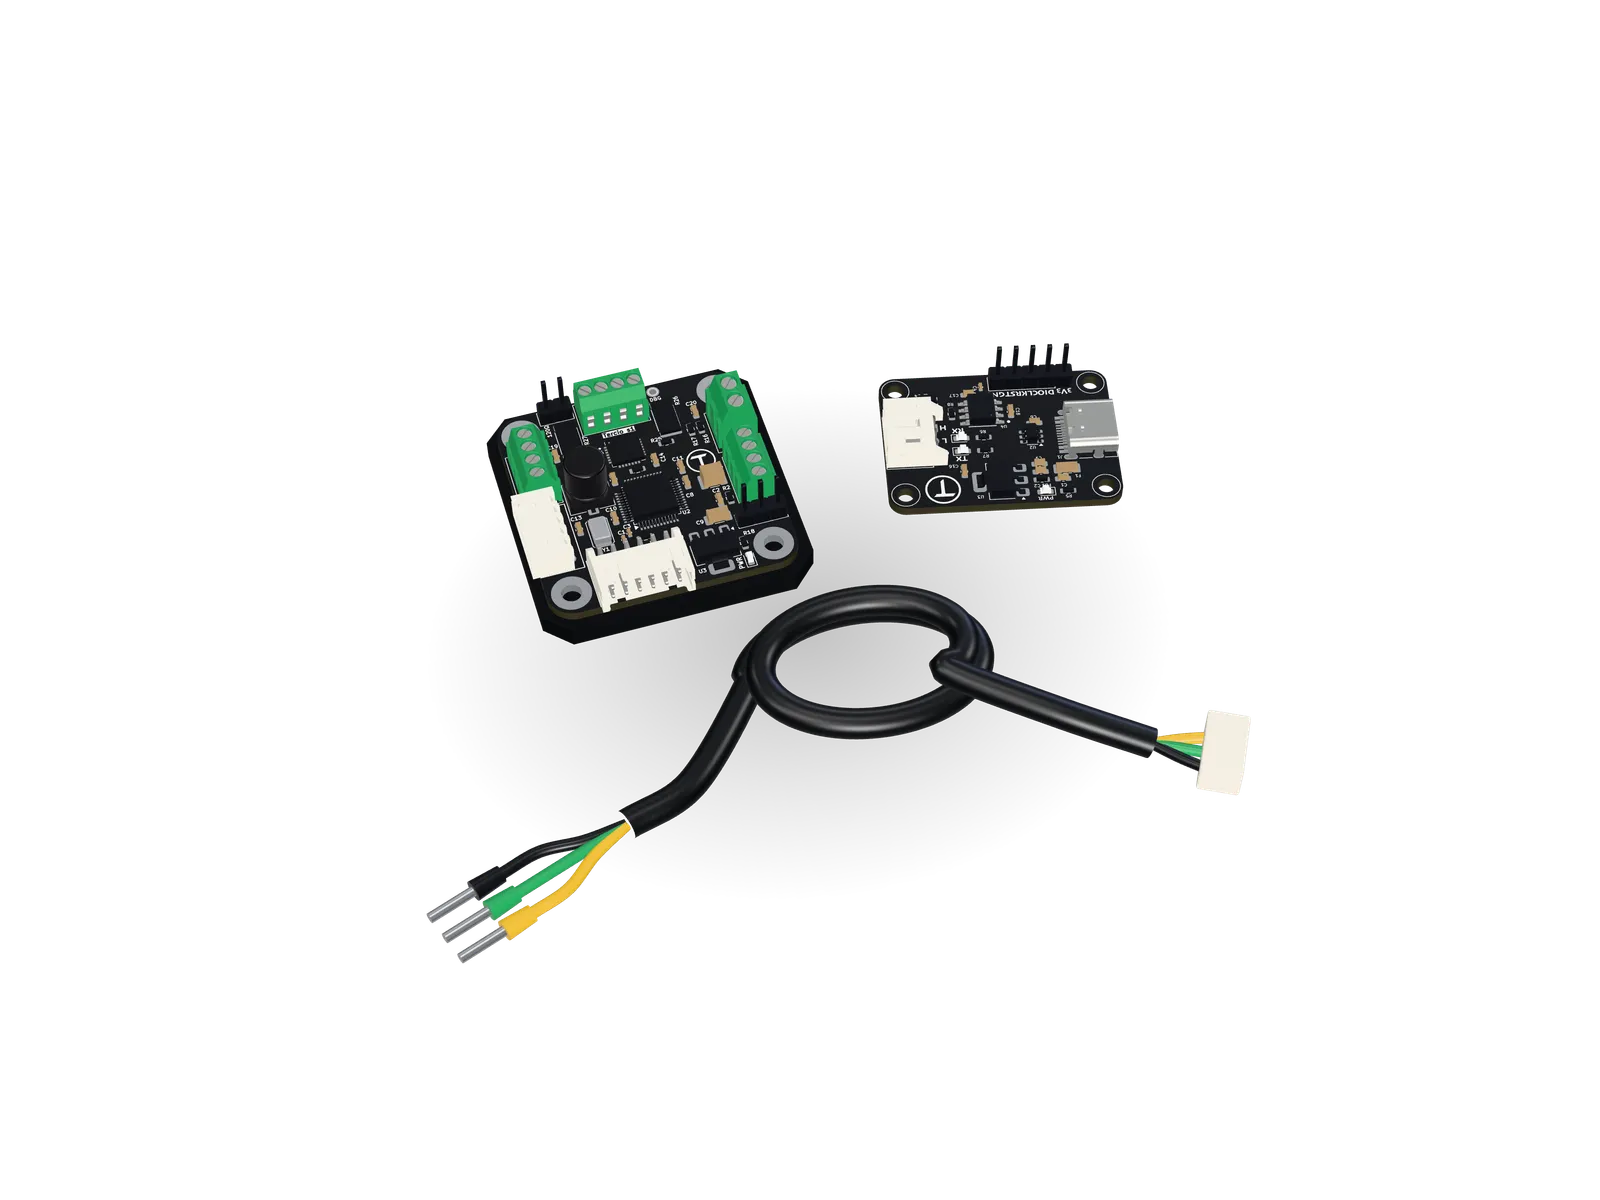
  • Tercio S1 driver board

Control

Processor
STM32G431, Arm Cortex-M4F at 170 MHz
Position loop
20 kHz, trapezoidal motion planner
Procedures
Encoder calibration, homing, speed-limit auto-tune
Protection
Stall detection, over-temperature shutdown, command timeout

Motor driver

Driver
Trinamic TMC2209
Current
Up to 1.77 A RMS per coil (2.5 A peak), set in software
Microstepping
Up to 1/256, StealthChop and SpreadCycle
Motor
Bipolar stepper, NEMA 17 mounting

Feedback

On-board encoder
AS5600, 12-bit (4,096 counts per turn), on the underside
External encoder
AS5048A (SPI, 14-bit) or AS5600 (I²C), 12-pin connector

Interfaces

Bus
CAN-FD, 500 kbit/s arbitration and 2.5 Mbit/s data
Nodes
Up to 127 per bus, 120 Ω termination by jumper
Step/dir
STEP, DIR and EN inputs, 3.3 V logic only
Inputs
Two limit or home switch inputs

Physical

Supply
12–28 V DC
Board
38 × 38 mm
Connectors
Screw terminals: 3.5 mm for power, 2.54 mm for motor, CAN and switches. JST PH (step/dir), JST PHD 12-pin (external encoder)

Your cart

Your cart is empty.

The store opens on 1 December 2026. Get an email the moment it does.

Launching 1 December 2026

Be first when we open

Leave your email and we’ll write once, the moment orders open. Pick what you’re interested in so we can plan stock.

What are you interested in?

Get 20% off your first order at launch. A confirmation with your code now, one email when the store opens, nothing else. Unsubscribe any time.